

Research
Featured Projects
A Safety-Aware Shared Autonomy Framework with BarrierIK Using Control Barrier Functions
 Shared autonomy blends operator intent with autonomous assistance, but in cluttered environments, linearly
blending individually collision-free commands can still produce unsafe motion. Most prior approaches only
enforce obstacle avoidance as a soft constraint through potentials or cost terms. In this work, we introduce
BarrierIK, which embeds control barrier functions (CBFs) directly into the inverse kinematics (IK) layer of
shared autonomy, enforcing safety as a hard constraint while remaining compatible with standard IK objectives
such as pose tracking, joint limits, and smoothness. We evaluate BarrierIK in simulation on cluttered
manipulation scenes and in a VR teleoperation user study comparing pure teleoperation with shared autonomy.
Across conditions, filtering blended commands through CBFs at the IK layer reduces safety-violation time and
increases minimum clearance while preserving task performance; participants also reported higher perceived
safety and trust, lower interference, and an overall preference for shared autonomy with our safety filter.
-
My Contributions:
- Formulated and implemented
BarrierIK, a control-barrier-function-constrained inverse kinematics solver that enforces post-blend safety as a hard inequality constraint alongside standard IK objectives. - Designed and ran the simulation benchmarks in cluttered environments, evaluating safety-violation time and minimum clearance against baseline shared-autonomy blending.
- Designed and conducted the
VRteleoperation user study comparing pure teleoperation with CBF-filtered shared autonomy. - Analyzed the objective (clearance, violation time, task performance) and subjective (trust, perceived safety, interference) study results.
B. Guler, K. Pompetzki, Y. Sun, S. Manschitz, and J. Peters, “A Safety-Aware Shared Autonomy Framework with BarrierIK Using Control Barrier Functions,” IEEE International Conference on Robotics and Automation (ICRA), 2026. Available:
arXiv Project Page
AssistDLO: Assistive Teleoperation for Deformable Linear Object Manipulation
Manipulating Deformable Linear Objects (DLOs) such as ropes and cables is challenging in robotics due to
their infinite-dimensional configuration space and complex nonlinear dynamics, and in teleoperation, depth
uncertainty further hinders state perception and reaction. AssistDLO addresses this as an assistive
teleoperation framework that combines real-time multi-view state estimation, visual assistance (VA), and a
geometry-aware shared-autonomy controller based on Control Barrier Functions (SA-CBF). Unlike traditional
shared-autonomy methods that rely on simple geometric attractors and can fail to preserve DLO geometry,
SA-CBF acts as a geometry-aware funnel that facilitates precise grasping while preserving the operator's
high-level authority. The framework was evaluated in a bimanual knot-untangling user study (N = 22) using
ropes of varying length and rigidity: SA-CBF provides the strongest gains for novice users, acting as a
skill equalizer that increases task success from 71% to 88%, and is most effective on stiffer ropes, while
expert users and highly compliant, long ropes benefit more from visual assistance — showing that
effective DLO teleoperation requires adaptive, user- and material-aware shared autonomy rather than a fixed
assistance strategy.
-
My Contributions:
- Designed the
AssistDLOframework, combining real-time multi-view DLO state estimation with a geometry-aware shared-autonomy controller. - Formulated the
SA-CBFshared-autonomy controller as a geometry-aware safety funnel around the estimated DLO state for precise, collision-aware grasping. - Designed and ran the bimanual knot-untangling user study (N = 22) across ropes of varying length and rigidity, comparing visual assistance and shared autonomy against unassisted teleoperation.
- Analyzed how assistance effectiveness depends on operator expertise and DLO material properties.
B. Guler, S. Manschitz, K. Pompetzki, and J. Peters, “AssistDLO: Assistive Teleoperation for Deformable Linear Object Manipulation,” arXiv preprint arXiv:2605.06323, 2026. Available:
arXiv
Robot-Assisted Drilling on Curved Surfaces with Haptic Guidance under Adaptive Admittance Control
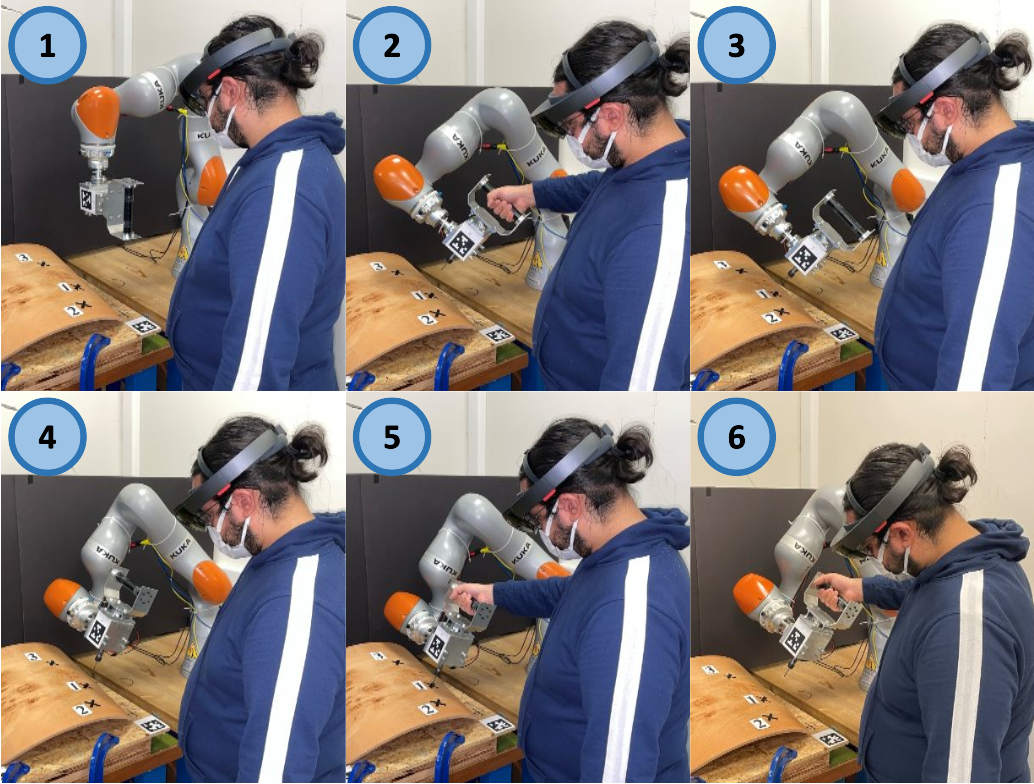 Drilling a hole on a curved surface with a desired angle is prone to failure when done manually, due to
the difficulties in drill alignment and also inherent instabilities of the task, potentially causing injury and
fatigue to the workers. On the other hand, it can be impractical to fully automate such a task in real
manufacturing environments because the parts arriving at an assembly line can have various complex
shapes where drill point locations are not easily accessible, making automated path planning difficult.
In this work, an adaptive admittance controller with 6 degrees of freedom is developed and deployed
on a KUKA LBR iiwa 7 cobot such that the operator is able to manipulate a drill mounted on the robot
with one hand comfortably and open holes on a curved surface with haptic guidance of the cobot and
visual guidance provided through an AR interface.
-
My Contributions:
- Developed an admittance controller in
C++usingFast Robot Interface (FRI)ofKUKA iiwa co-bot. - Developed an mixed reality (MR) interface in
C#, working withMicrosoft HoloLens, usingUnity Game EngineandMicrosoft's Mixed Reality Toolkit (MRTK). - Implemented a
Kalman Filterto track 6-DoF movements of HoloLens and the workpiece being drilled via visual fiducial markers (AprilTag) attached to them. - Constructed a 3D mesh model of the workpiece using a
depth camera (Microsoft Kinect). - Established a
TCPcommunication between the robot and HoloLens.
A. Madani, P. P. Niaz, B. Guler, Y. Aydin, and C. Basdogan, “Robot-Assisted Drilling on Curved Surfaces with Haptic Guidance under Adaptive Admittance Control” IROS, 2022. Available:
An adaptive admittance controller for collaborative drilling with a robot based on subtask classification via deep learning
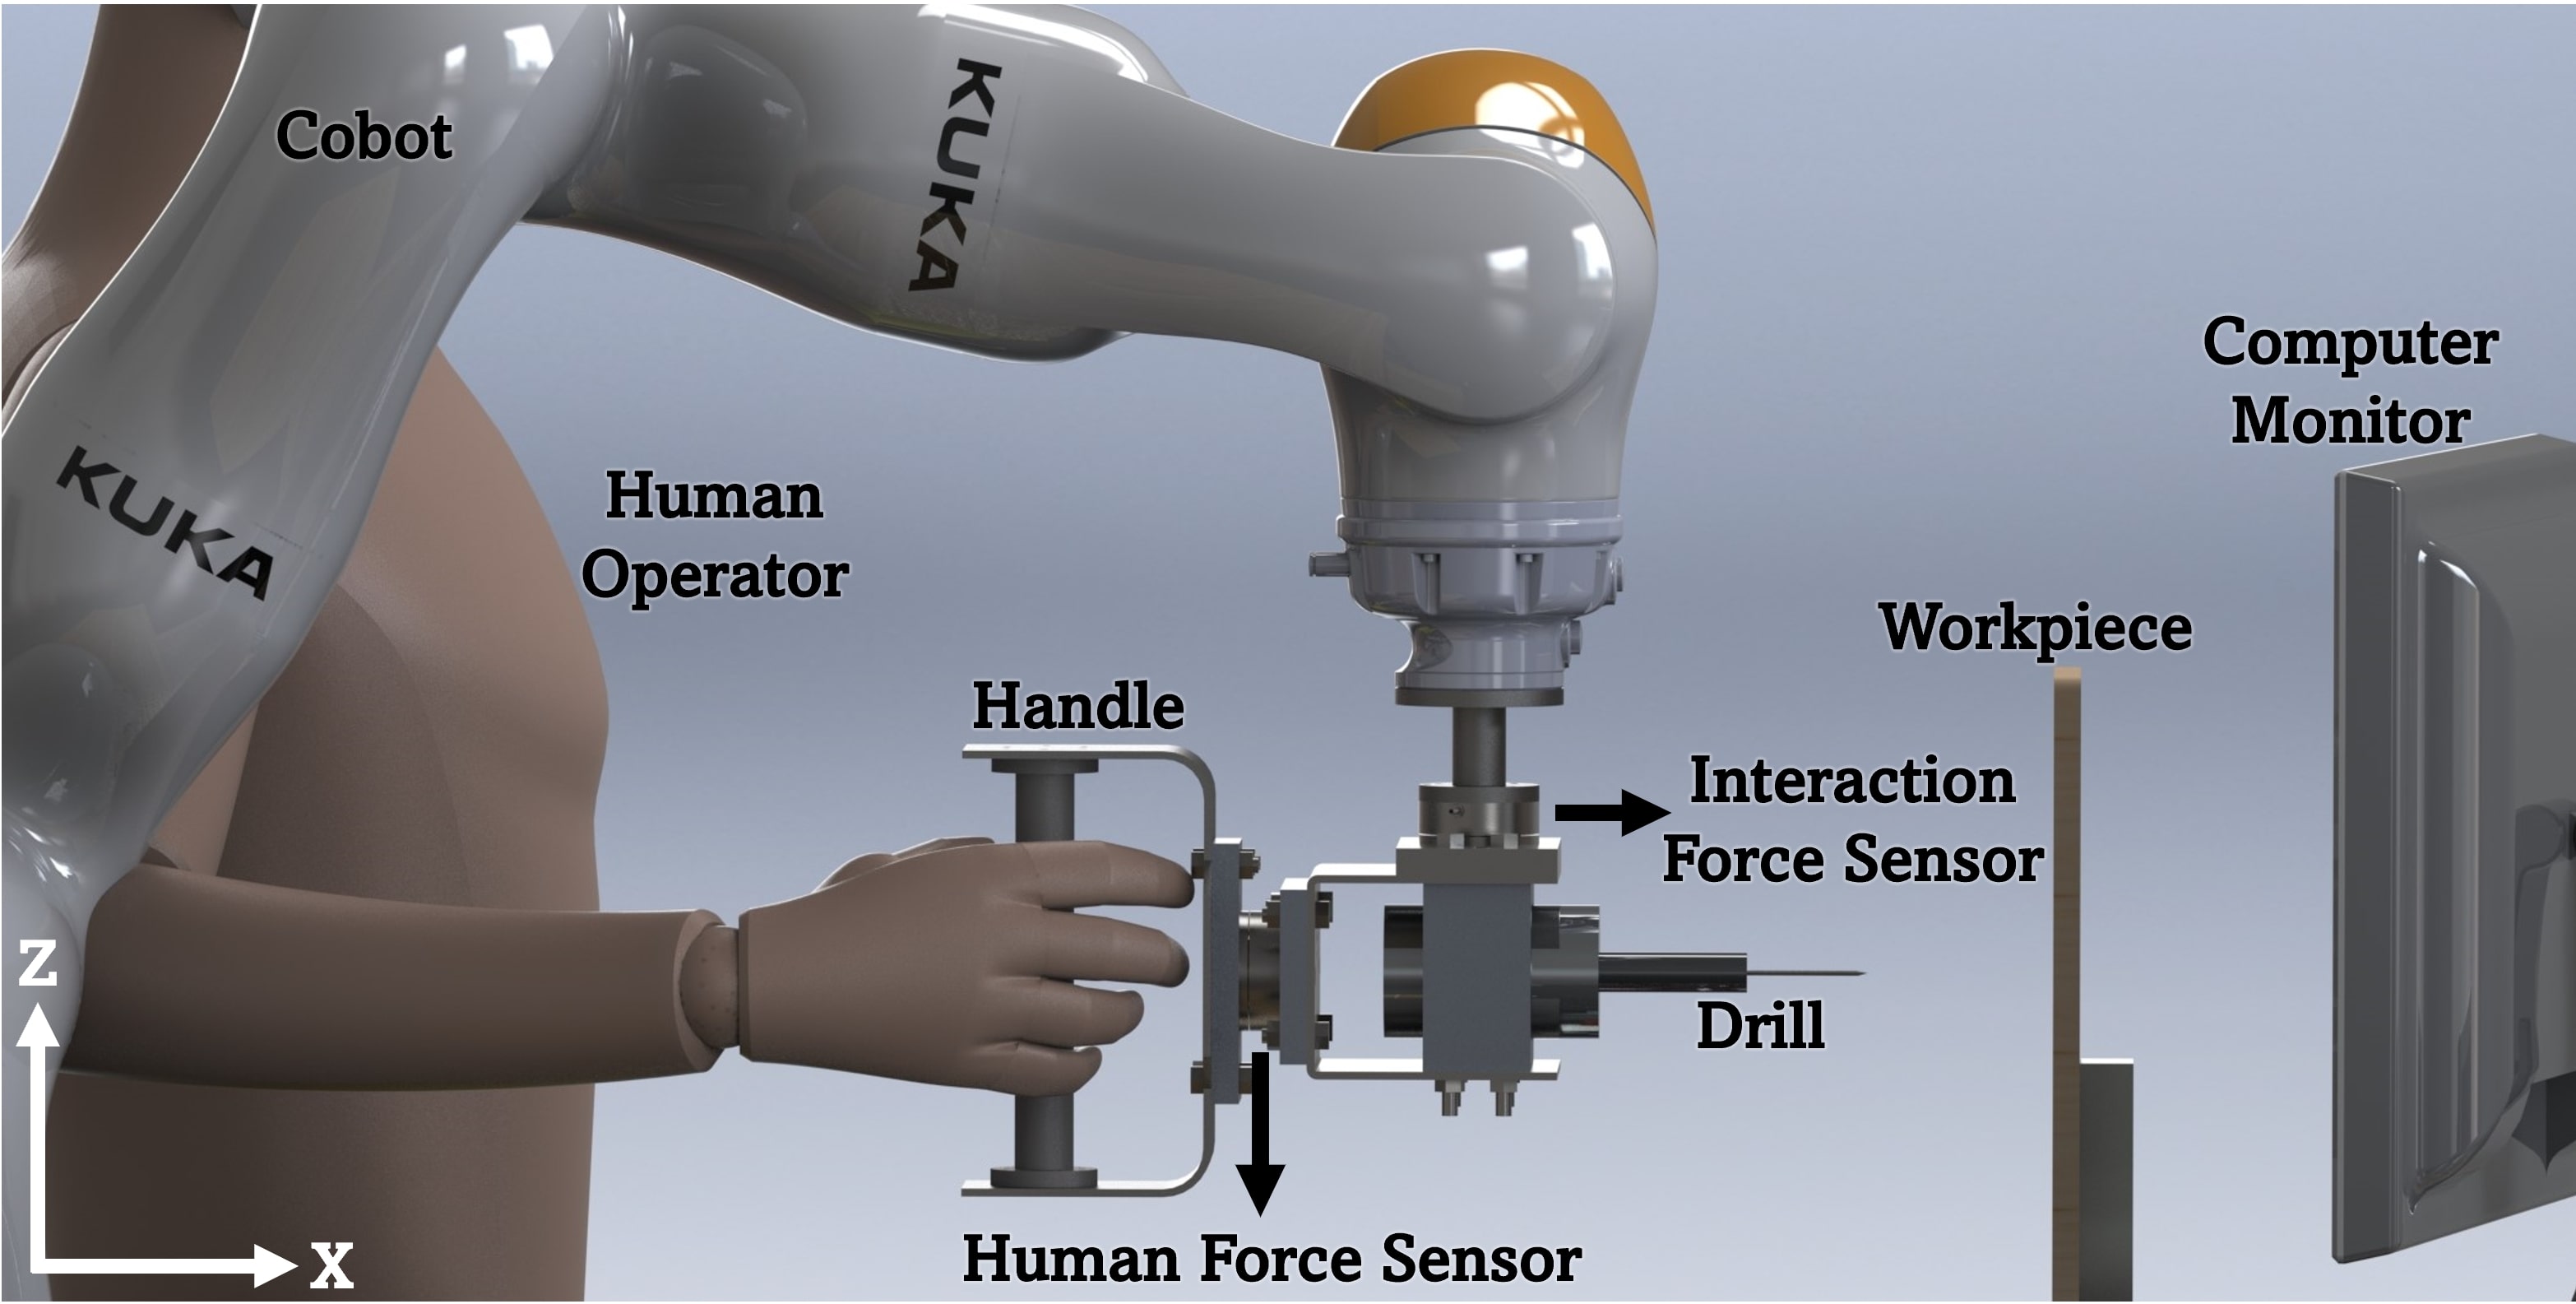 In this paper, we propose a supervised learning approach based on an Artificial Neural Network (ANN) model for real-time classification of subtasks in a physical human-robot interaction (pHRI) task involving contact with a stiff environment. In this regard, we consider three subtasks for a given pHRI task: Idle, Driving, and Contact. Based on this classification, the parameters of an admittance controller that regulates the interaction between human and robot are adjusted adaptively in real-time to make the robot more transparent to the operator (i.e., less resistant) during the Driving phase and more stable during the Contact phase. The Idle phase is primarily used to detect the initiation of the task.
-
My Contributions:
- Developed a control architecture for regulating the physical interactions between human and a robot (pHRI) via an admittance controller implemented on
KUKA iiwa co-bot. - Performed a linear time-varying stability analysis for the pHRI system.
- Developed a
deep learning (DL)model to classify the subtasks of a task using theTensorflowframework inPython. - Developed methods to adapt the parameters of the admittance controller based on the outcome of the DL model.
- Developed a graphical user interface (GUI) in
C#for reading and recording data fromATI force sensors. - Designed pHRI experiments, collected data, and performed statistical analysis on the data.
B. Guler, P. P. Niaz, A. Madani, Y. Aydin, and C. Basdogan, “An adaptive admittance controller for collaborative drilling with a robot based on subtask classification via deep learning” Mechatronics, vol. 86, p. 102851, 2022. Available:
Autonomous Manipulation and SLAM with the Hybrid Mobile Manipulator
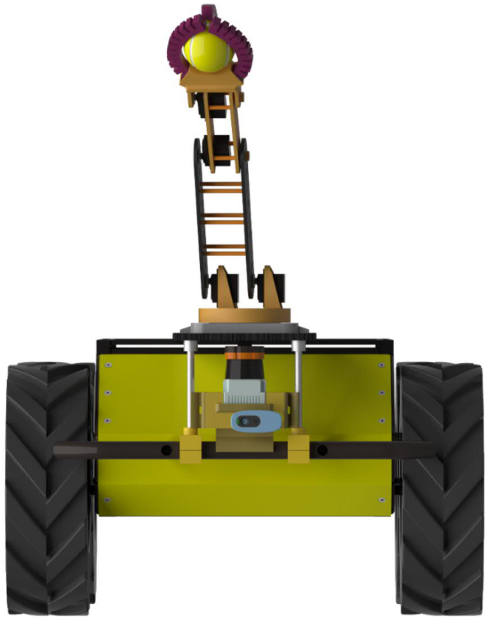 This study demonstrates the soft robotic as a part of the mobile manipulator that executes the defined tasks, which are listed below:
- Autonomous Navigation using SLAM.
- The visual recognition of the marked boxed with ARtags.
- Pick&Place manipulation of the objects located on top of the marked boxes.
-
My Contributions:
- Designed a serial robotic manipulator using
Siemens NXand manufactured it using 3-D printing technology. - Designed a soft gripper using
PneuNets, and analyzed by utilizing finite element methods usingAbaqus. - Integrated the robotic manipulator with a mobile platform.
- Developed the
ROS packagesfor the manipulator inPython. - Tracked the positions of the marked boxes using visual fiducial markers (ARTag) attached to the box using
OpenCV. - Implemented a
SLAMalgorithm fromROS Navigation Stackto estimate the pose of the mobile platform usingLIDARandIMU.
Autonomous Visual Fiducial Markers Recognition and Tracking
Approaching the Visual Fiducial Marker
Inverse Kinematics
Deep Reinforcement Learning to Optimize Task Performance in Human-Robot Co-Manipulation
In industry, complex tasks encourage human operators to work together with robots, and carrying heavy objects is one of them.
Using the human's dexterity and intelligence and the robot's precision, we can drive and park heavy objects where the human operator wants without the programming in advance.
This study's initial aim is to increase efficiency by understanding human motion intention.
However, the human force's response is observed by delay due to the object's weight.Therefore, estimated human intention can help make decisions on amplifying or attenuating the human force.
Constantly scaling in one way is not efficient for human effort because of the different phases of the co-manipulation task. Amplification is preferable during driving when attenuation becomes more of an issue for parking.
The deep learning model provides an adaptive force scaling factor by referring to human motion intention without guaranteeing optimal human effort and comfort.
The model-free optimal control algorithm, deep reinforcement learning, adjusts the existing adaptive force scaling factor to decrease human effort and increase comfort.
-
My Contributions:
- Developed an experimental set-up for human-robot co-manipulation of a heavy object.
- Developed a
deep learning (DL)model usingTensorflowinPythonto estimate human intention to accelerate/decelerate the manipulated object. - Developed a
deep reinforcement learning (DRL)model, working with the DL model, to optimize task performance based on minimum jerk and human effort. - Designed pHRI experiments, collected data, and performed statistical analysis on the data.
B. Guler, “Deep Reinforcement Learning to Optimize Task Performance in Human-Robot Co-Manipulation,” M.S. Thesis, Koç University, 2023.
Full Publication List
An up-to-date list is also maintained on my Google Scholar profile.
Journal Articles
-
B. Guler, P. P. Niaz, A. Madani, Y. Aydin, and C. Basdogan, “An adaptive admittance controller for collaborative drilling with a robot based on subtask classification via deep learning,” Mechatronics, vol. 86, p. 102851, 2022.
arXiv
Conference Papers
-
B. Guler, K. Pompetzki, Y. Sun, S. Manschitz, and J. Peters, “A Safety-Aware Shared Autonomy Framework with BarrierIK Using Control Barrier Functions,” in IEEE International Conference on Robotics and Automation (ICRA), 2026.
arXiv Project Page -
S. Manschitz, B. Guler, W. Ma, and D. Ruiken, “Sampling-Based Grasp and Collision Prediction for Assisted Teleoperation,” in IEEE International Conference on Robotics and Automation (ICRA), 2025.
arXiv -
B. Guler, K. Pompetzki, S. Manschitz, and J. Peters, “Towards Assistive Teleoperation for Knot Untangling,” in German Robotics Conference (GRC), 2025.
PDF -
A. Madani, P. P. Niaz, B. Guler, Y. Aydin, and C. Basdogan, “Robot-Assisted Drilling on Curved Surfaces with Haptic Guidance under Adaptive Admittance Control,” in IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022.
arXiv
Workshop Papers
-
G. Wigginghaus, T. Missal, B. Guler, S. Manschitz, and J. Peters, “Learning Sim-Grounded Policies for Bimanual Rope Manipulation from Human Teleoperation Data,” in 1st ICRA Workshop on Beyond Teleoperation, 2026.
arXiv
Preprints
-
B. Guler, S. Manschitz, K. Pompetzki, and J. Peters, “AssistDLO: Assistive Teleoperation for Deformable Linear Object Manipulation,” arXiv:2605.06323, 2026.
arXiv -
T. Missal, L. Domingues, B. Guler, S. Manschitz, J. Peters, and P. D. P. Costa, “RopeDreamer: A Kinematic Recurrent State Space Model for Dynamics of Flexible Deformable Linear Objects,” arXiv:2604.28161, 2026.
arXiv
Thesis
- B. Guler, “Deep Reinforcement Learning to Optimize Task Performance in Human-Robot Co-Manipulation,” M.S. Thesis, Koç University, 2023.