Autonomous Manipulation and SLAM with a Hybrid Mobile Manipulator
B.Sc. Thesis, Istanbul Technical University, 2020
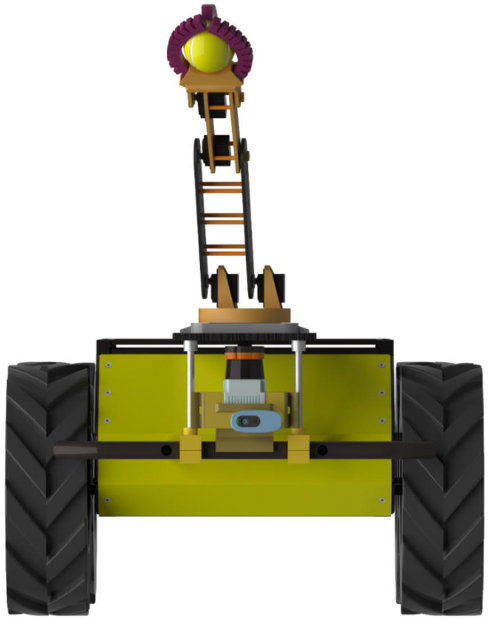
This study demonstrates the soft robotic as a part of the mobile manipulator that executes the defined tasks: autonomous navigation using SLAM, the visual recognition of the marked boxes with ARtags, and pick-and-place manipulation of the objects located on top of the marked boxes.
AI-generated summary · may contain mistakes, see the paper
For my B.Sc. thesis, supervised by Prof. Hakan Temeltaş, I built a mobile manipulator that combines a rigid, 3D-printed arm with a soft pneumatic gripper, and demonstrated it on autonomous navigation with SLAM, visual recognition of AR-tagged boxes, and pick-and-place of the objects on top of them.
My contributions
- Designed a serial robotic manipulator in Siemens NX and manufactured it with 3D printing.
- Designed a soft PneuNets gripper and analyzed it with finite element methods in Abaqus.
- Integrated the manipulator with the mobile platform.
- Developed the ROS packages for the manipulator in
Python. - Tracked the marked boxes from ARTag fiducial markers with
OpenCV. - Used SLAM from the ROS Navigation Stack to estimate the platform pose from LIDAR and IMU.
Videos
The full report is also available as a web page.